NYU's Deep Learning Collision Prediction Project
Description: Deep learning project for predicting collisions
Info: The model takes 11 consecutive images of objects (varying shape, color, and material) moving on a smooth white surface. The model must predict the segmentation mask of the scene after another 11 frames. We used a dual UNet model (WNet) to predict object positions accurately.
What I focused on:
- WNet, a dual-UNet model that predicts the segmentation mask 11 frames ahead.
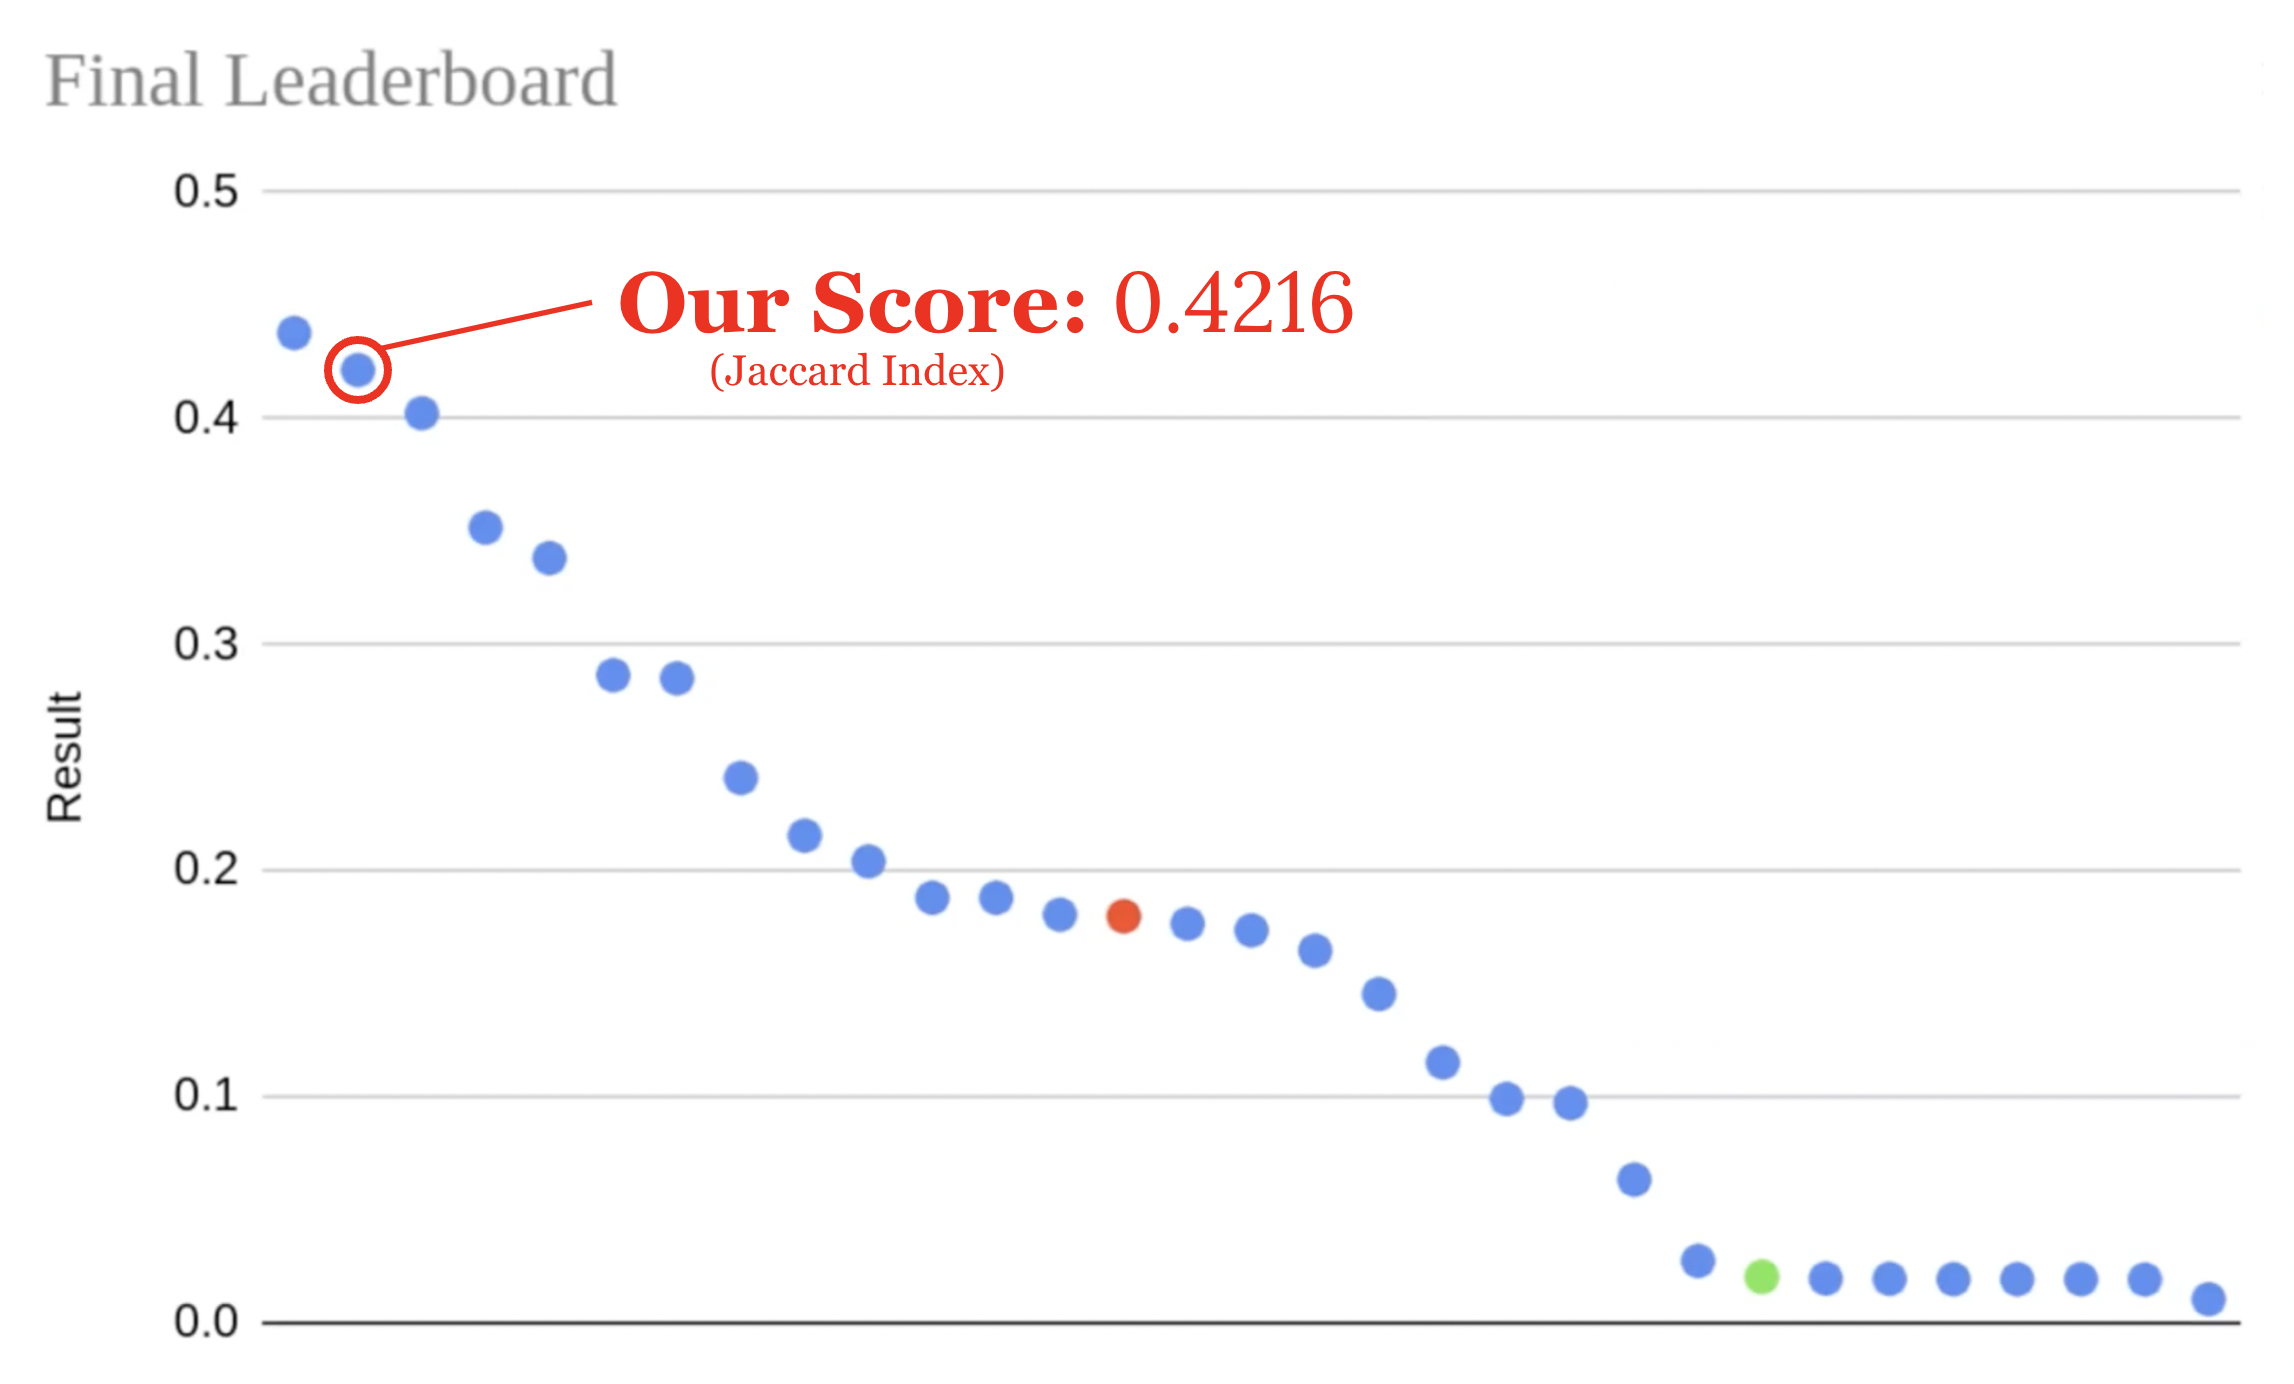
- 2nd place in Yann LeCun's class challenge (0.442 Jaccard).